publications
2026
- PhysWMCLAW: Learning Continuous Latent Action World Models via Adversarial Latent RegularizationIn CoRL Workshop PhysWM, 2026Takeaway: end-to-end continuous latent actions + diffusion world model from action-free video; 43% RoboDesk upright-block planning vs. 5% AdaWorld; 1.7/3.0 long-horizon real UR5 vs. 1.5 AdaWorld.
- What Are We Actually Benchmarking in Robot Manipulation?In Proceedings of the Conference on Robot Learning (CoRL), 2026Takeaway: four diagnostics showing popular manipulation benchmarks often fail as proxies for general capability; reference implementations released.
2025
- PROGRESSOR: A Perceptually Guided Reward Estimator with Self-Supervised Online RefinementIn Proceedings of the IEEE/CVF International Conference on Computer Vision (ICCV), 2025Takeaway: self-supervised visual progress reward with online push-back; Meta-World RL without env reward; real-UR5 few-shot offline RL under noisy demos.
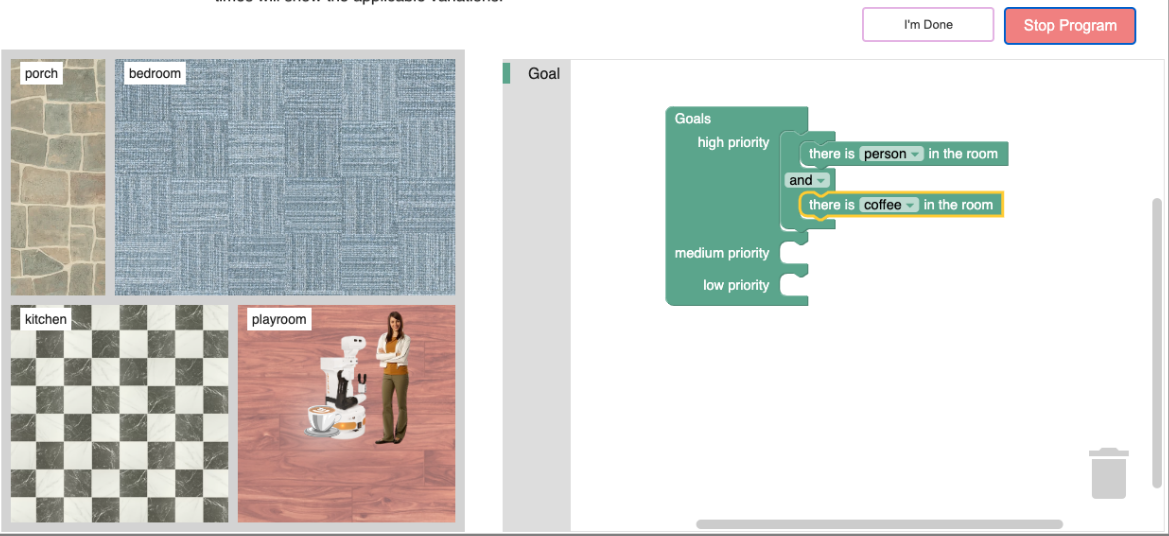
- Enabling End Users to Program Robots Using Reinforcement LearningIn Proceedings of the ACM/IEEE International Conference on Human-Robot Interaction (HRI), 2025

2021
-
 Automatic Microplot Localization Using UAV images and a Hierarchical Image-based Optimization MethodPlant Phenomics, 2021
2020
-
 Unsupervised Domain Adaptation for Plant Organ CountingIn Proceedings of the European Conference on Computer Vision (ECCV), 2020
-
 AutoCount: Unsupervised Segmentation and Counting of Organs in Field ImagesIn Proceedings of the European Conference on Computer Vision (ECCV), 2020